The Duet boards use bipolar stepper motor drivers. This means you can use stepper motors suitable for bipolar drive, which have 4, 6 or 8 wires. You cannot use motors with 5 wires, because those are intended to be driven in unipolar mode only. (Some unipolar motors can be made into bipolar motors by cutting a trace on a circuit board.)
Unless you will be using external stepper motor drivers, choose motors with rated current of at least 1.2A, and at most 2.0A for the Duet 0.6 and Duet 0.8.5, or 3A for the Duet 2.
Plan to run each stepper motor at between 50% and 85% of its rated current.
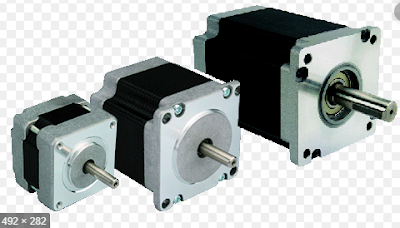
Size: Nema 17 is the most popular size used in 3D printers. Nema 14 is an alternative in a highly-geared extruder. Use Nema 23 motors if you cannot get sufficient torque from long Nema 17 motors.
Avoid motors with rated voltage (or product of rated current and phase resistance) > 4V or inductance > 4mH.
Choose 0.9deg step motors where you want extra positioning accuracy, e.g. for the tower motors of a delta printer. Otherwise choose 1.8deg step motors.
If you use any 0.9deg/step motors, or high torque motors, use 24V power so that you will be able to maintain torque at higher speeds.
If using a highly-geared extruder (for example, an extruder that uses a flexible drive cable to transmit the torque from the motor to a worm reduction gear), use a short low-inductance 1.8deg/step motor to drive it.
Unless you will be using external stepper motor drivers, choose motors with rated current of at least 1.2A, and at most 2.0A for the Duet 0.6 and Duet 0.8.5, or 3A for the Duet 2.
Plan to run each stepper motor at between 50% and 85% of its rated current.
Size: Nema 17 is the most popular size used in 3D printers. Nema 14 is an alternative in a highly-geared extruder. Use Nema 23 motors if you cannot get sufficient torque from long Nema 17 motors.

Avoid motors with rated voltage (or product of rated current and phase resistance) > 4V or inductance > 4mH.
Choose 0.9deg step motors where you want extra positioning accuracy, e.g. for the tower motors of a delta printer. Otherwise choose 1.8deg step motors.
If you use any 0.9deg/step motors, or high torque motors, use 24V power so that you will be able to maintain torque at higher speeds.
If using a highly-geared extruder (for example, an extruder that uses a flexible drive cable to transmit the torque from the motor to a worm reduction gear), use a short low-inductance 1.8deg/step motor to drive it.
评论
发表评论